AMD Schola is an open-source Unreal Engine plugin that brings standard Gymnasium-compatible RL training directly into the Unreal Editor, connecting to Python training frameworks over gRPC.
Unreal Robotics Lab (URLab) is a plugin that embeds MuJoCo inside Unreal, letting you define robots in the MuJoCo XML format (MJCF) and drive them with fast, accurate contact physics.
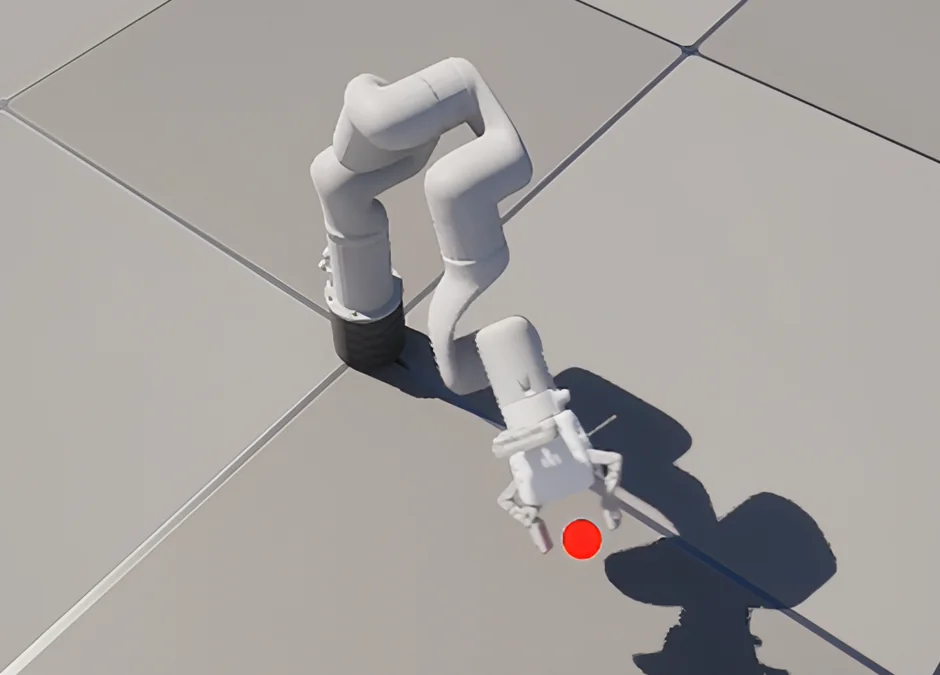
The bundled C++ source under source/ connects those two plugins in your game module, and together they form a pipeline that takes MuJoCo’s physics through Unreal’s rendering and tooling, with Schola exposing the result to a Python training loop on AMD hardware. This post walks through how that pipeline is structured and how to implement a reach task for a 6 degrees-of-freedom (DOF) robot arm from scratch.
A great reinforcement learning (RL) training environment excels along many axes. Unreal® Engine brings a powerful combination of capabilities, including physically based rendering, high-fidelity visual environments, and a mature toolset for building rich interactive scenes. These strengths make it an excellent fit for training tasks that involve complex lighting or rich vision-based observations.